SELF-PACED WORKSHOP
Teach Microduck to score a goal
Play with keyboard controls, learn training and perception, then connect the full autonomous task.
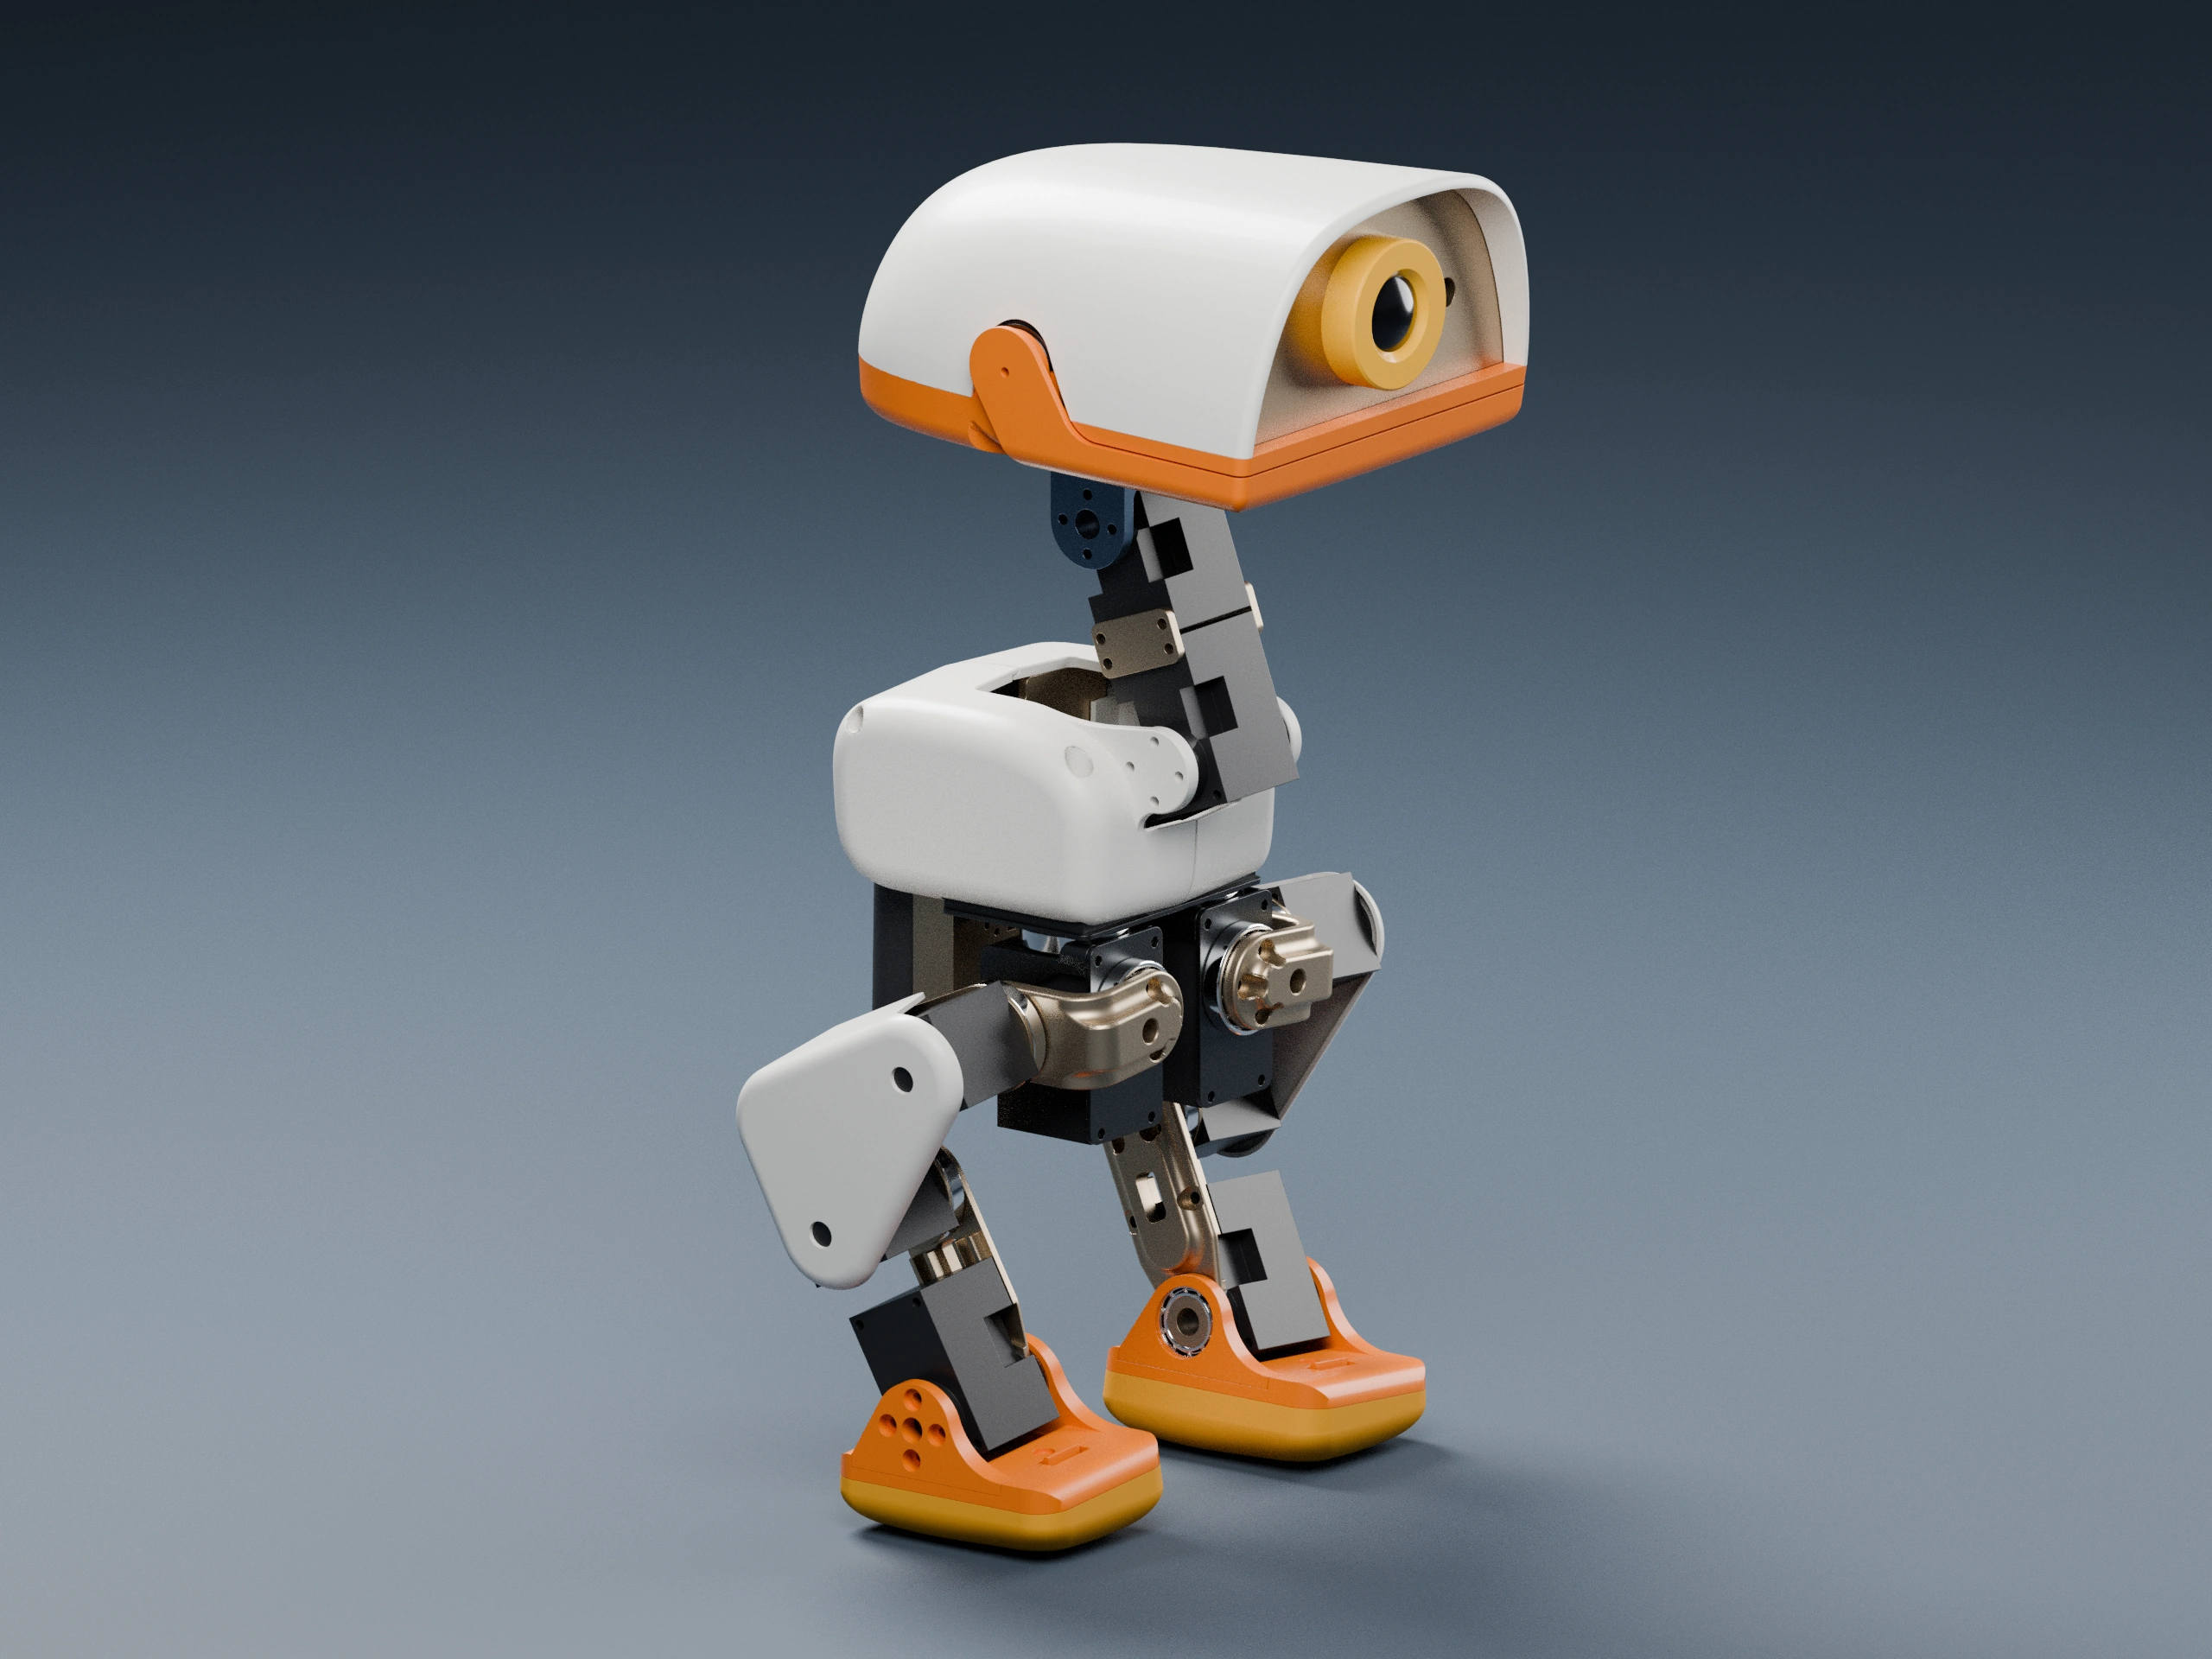
What you will build
The final scene contains one Microduck, one football, and one goal. The robot must find the ball, locate the goal, approach a useful kicking position, make contact, and recover its stance. You will learn what each part of this system does and how the parts work together.
- 1Understand the mechanism
- 2Control and train
- 3See and navigate
- 4Score autonomously
By the end, you can
- Explain how joints, actuators, observations, actions, and rewards relate.
- Launch a Newton / Isaac Lab simulation and inspect a fixed policy in action.
- Run a bounded training exercise, locate checkpoints, and interpret training curves.
- Connect camera detections, ToF ranges, and body attitude to autonomous task states.
- Record both successes and failures, distinguishing model metrics from task metrics.
Course route
| Chapter | Task |
|---|---|
| Chapter 1 | Meet Microduck: play football first |
| Chapter 2 | Mechanism and control timing |
| Chapter 3 | Learning to walk |
| Chapter 4 | Adapt walking to slopes |
| Chapter 5 | Explore community movement skills |
| Chapter 6 | Design the autonomous football pipeline |
| Chapter 7 | Complete the autonomous task |
| Chapter 8 | Recap and a harder football challenge |